The work
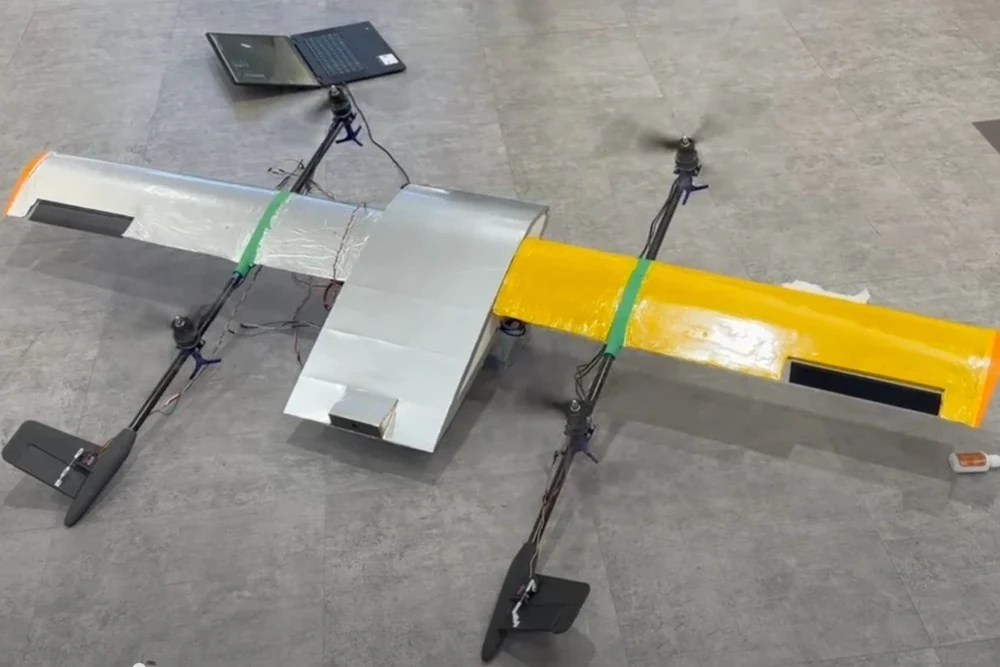
At StanfordUAV, I help lead the development of fixed-wing VTOL and multirotor aircraft. The work spans airframe design, avionics, perception, controls, manufacturing, and testing.
My contribution
I work across autonomy and system integration, including vision-based landing, embedded computing, sensor integration, and flight-test planning. Just as important is coordinating interfaces between the students building each part of the aircraft.
Engineering scope shown above describes areas of work. It does not specify a validated architecture or a performance result.
Across the stack
The engineering connects cameras and onboard computing with flight control, airframes, and testing. My current work includes visual landing and navigation, flight-computer integration, and the practical steps required to move from a subsystem to a complete aircraft.
Teaching through engineering
Through Stanford Student Robotics and DroneHacks, I also help create opportunities for students to build and test aerial systems together.
Fixed-wing aircraft for wildfire applications
I am developing fixed-wing VTOL aircraft for wildfire detection and response applications. This work is in development; the intended application is distinct from a completed wildfire-response deployment.
Indoor autonomy for search and rescue
I am developing indoor drones that navigate without GPS for search-and-rescue applications. The work focuses on perception, navigation, and systems integration; no completed rescue deployment is claimed.